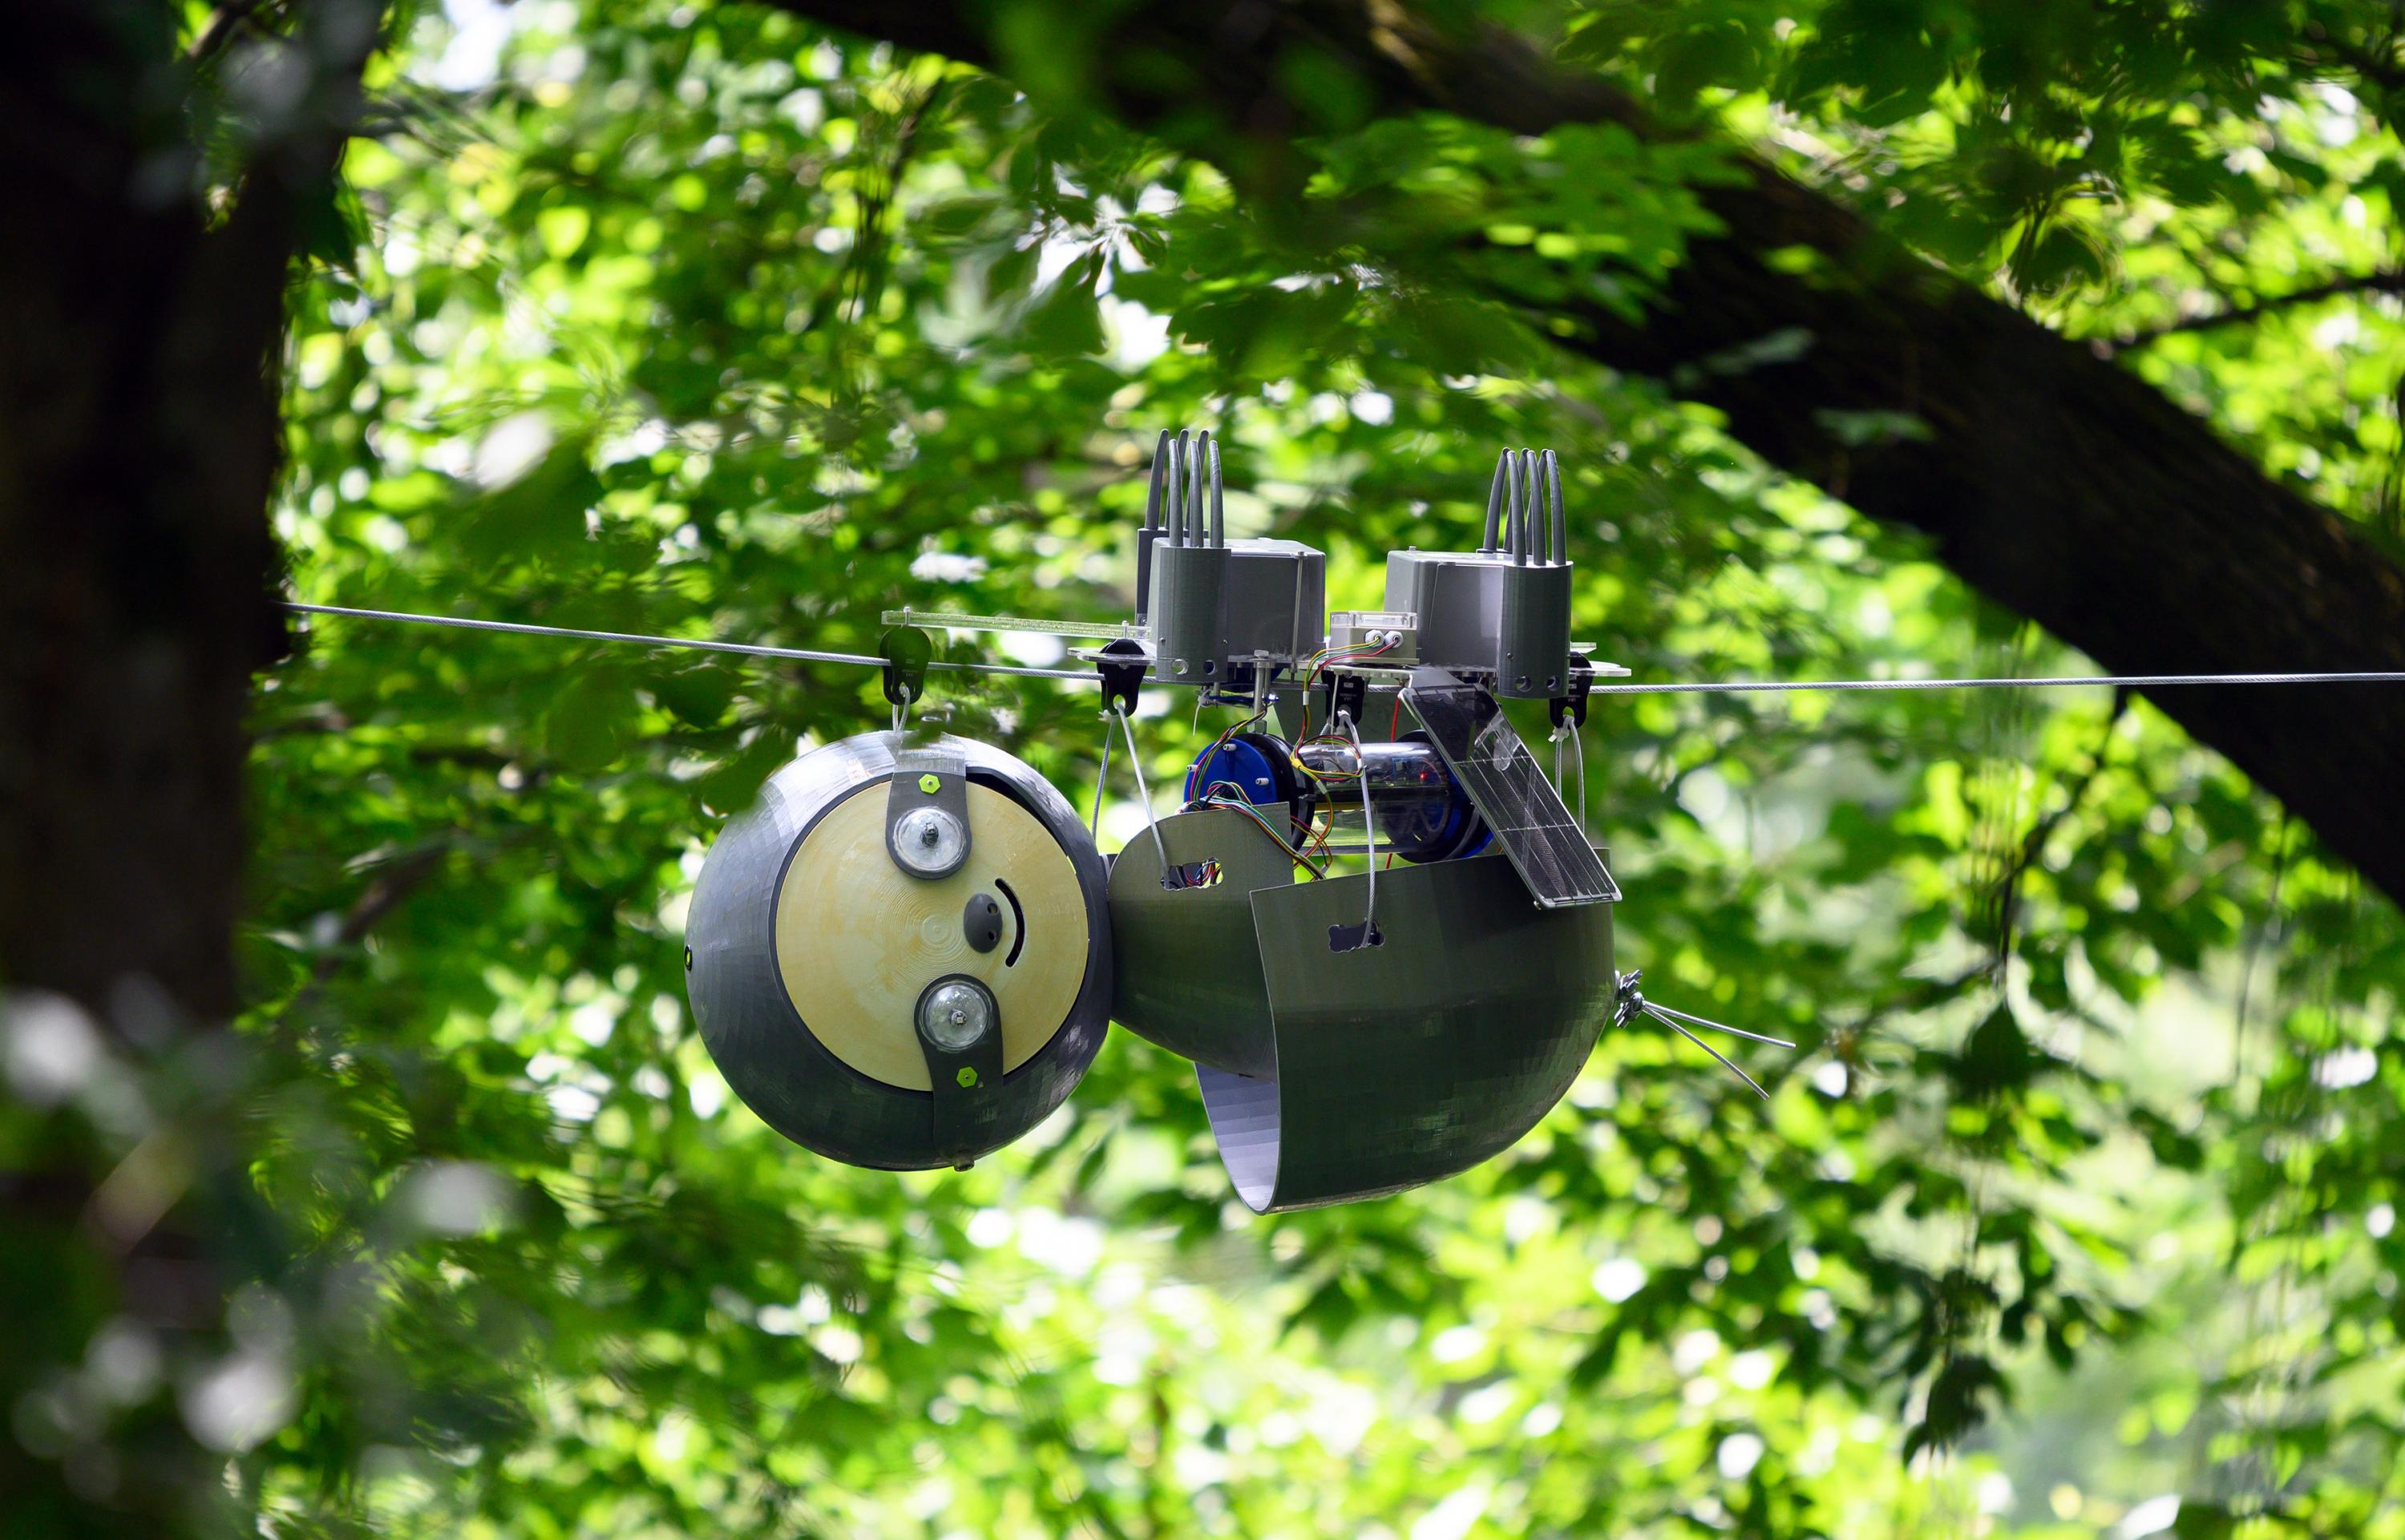
The SlothBot
A solar-powered, wire-traversing robot for environmental monitoring, deployed at the Atlanta Botanical Garden.
I work on learning-based planning and autonomous decision-making. My interests include imitation and reinforcement learning, uncertainty-aware autonomy, and control systems.
I earned my PhD in Robotics at Georgia Tech, advised by Magnus Egerstedt and Zsolt Kira. My research focused on safe learning and data-driven control for long-duration autonomy.
During my time at Georgia Tech, I also worked on the SlothBot and the Robotarium.
Current role: Senior Machine Learning Engineer
Autonomy & Mapping · Internship
Planning & Scheduling for Autonomous Teams · Internship
Superconductors & Devices · Internship
Georgia Institute of Technology
Machine Learning · Georgia Institute of Technology
Georgia Institute of Technology
A solar-powered, wire-traversing robot for environmental monitoring, deployed at the Atlanta Botanical Garden.
A remotely accessible swarm robotics testbed. My work included learning-compatible safety frameworks and wireless charging for autonomous experiments.
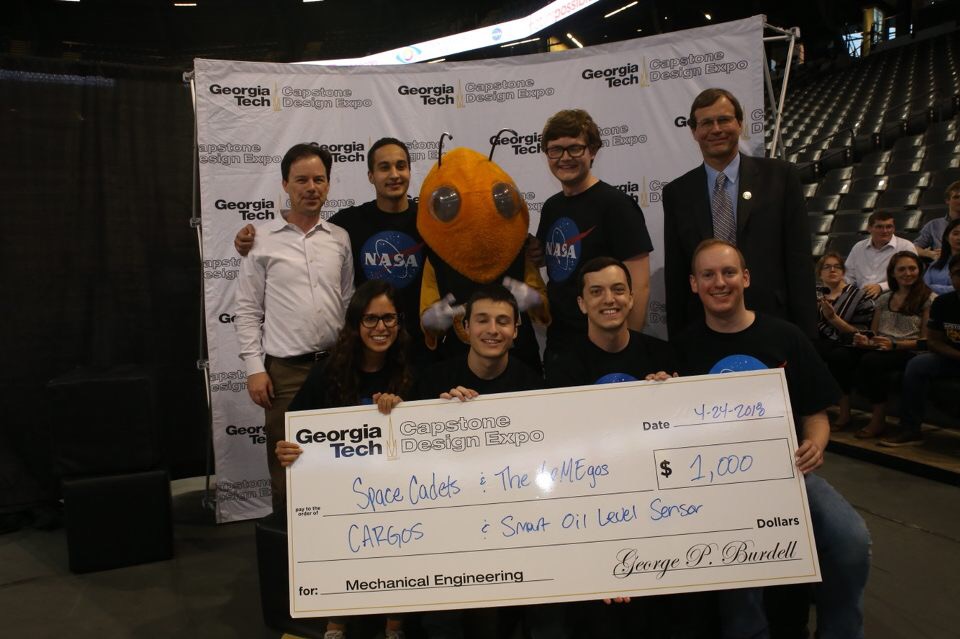
A Compact Active Response Gravity Offload System developed for a NASA capstone project. I worked on the interface and PID feedback loop. Our team received Georgia Tech’s Best Mechanical Engineering Project award.
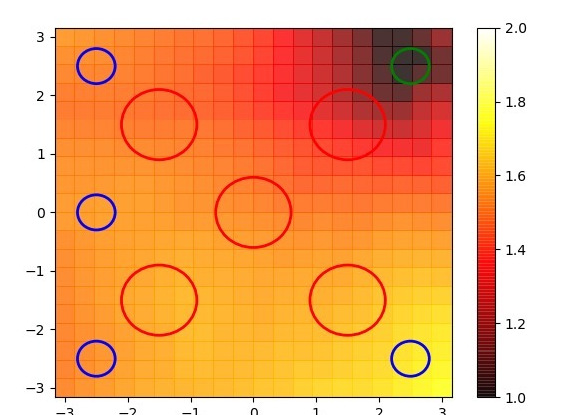
Combining reinforcement learning with robust control barrier functions to guide exploration under uncertain dynamics.
A differentiable safety layer combines reinforcement learning with robust control barrier functions, guiding exploration when the system dynamics are uncertain.
Gaussian-process estimates of disturbances inform robust control barrier functions, allowing robotic systems to adapt their safety constraints as they collect data.
Robot teams adapt task assignments using data about their capabilities and disturbances, with robust control barrier functions linking allocation and execution.
Adaptive assignment lets a heterogeneous team respond when robot capabilities change or are not fully known in advance.